Skip to content
recaplica

    One moment: security check

    Cloudflare wants to make sure you're not a robot. Tick the box below and your search will continue on its own.

    IT
    recaplica Solid Geometry: 3D Shapes and Their Formulas
    © 2026 Recaplica · recaplica.com — All rights reserved
    Home › Science

    Solid Geometry: 3D Shapes and Their Formulas

    By Recaplica Newsroom · Updated on September 20, 2026

    What to print

    Page numbers appear when printing with default margins.

    Slides

    Choose a cut

    Flash10 slidesThe essential thread, to present in classFull15 slidesEvery chapter and the deeper detail

    Both come with speaker notes.

    Telegram channel
    recaplica Clear in 30 seconds, yours in 10 minutes.
    In 30 seconds Key points Deep dive Slides Myths Mind map Quiz Flashcards FAQ

    In 30 seconds quick read

    Solid geometry is the branch of geometry that studies three-dimensional shapes: polyhedra, such as the cube and the pyramid, and solids of revolution, such as the cylinder, the cone, and the sphere. Every solid has its own formulas for surface area, the extent of its outer "skin," and volume, the space it occupies, built from measurements such as edges, radii, and heights. Where plane geometry works on a flat, two-dimensional surface, solid geometry adds depth, and each shape needs its own formula to match. Knowing these formulas is how you work out how much material a container needs or how much liquid it holds.

    Key Points

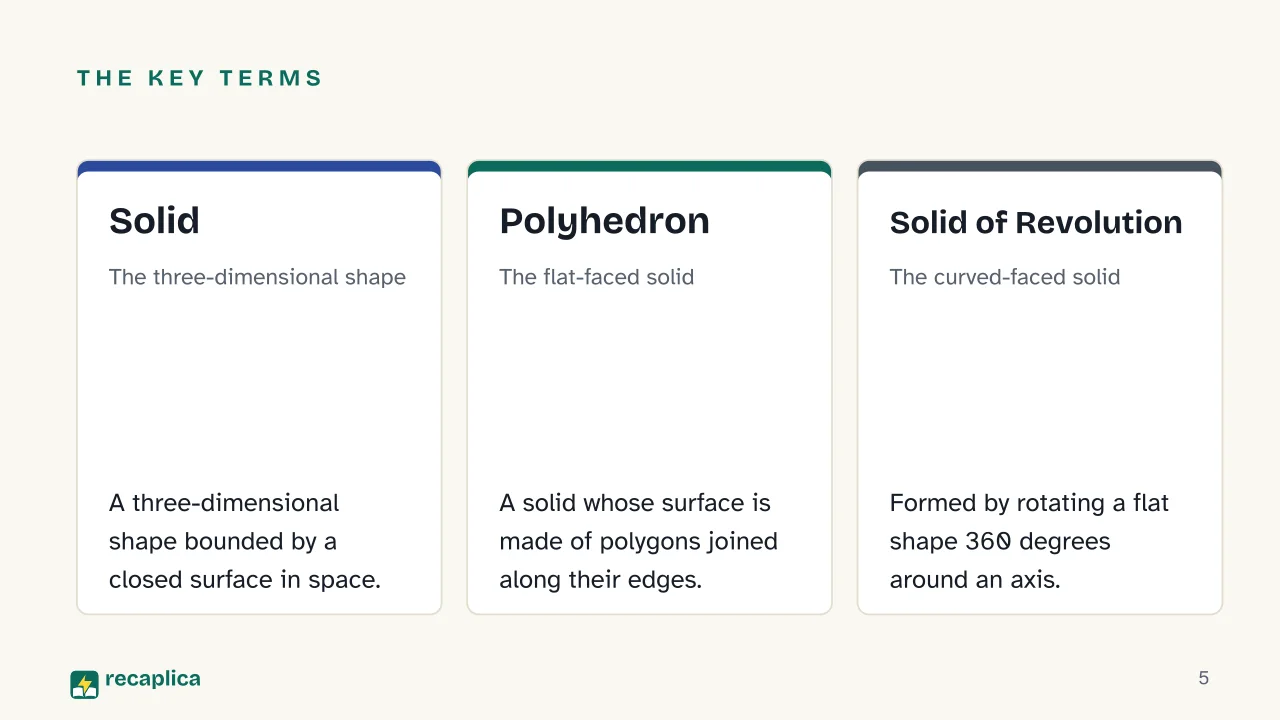
    • A solid is a three-dimensional shape bounded by a closed surface in space; when that surface is made of polygons, the solid is called a polyhedron.
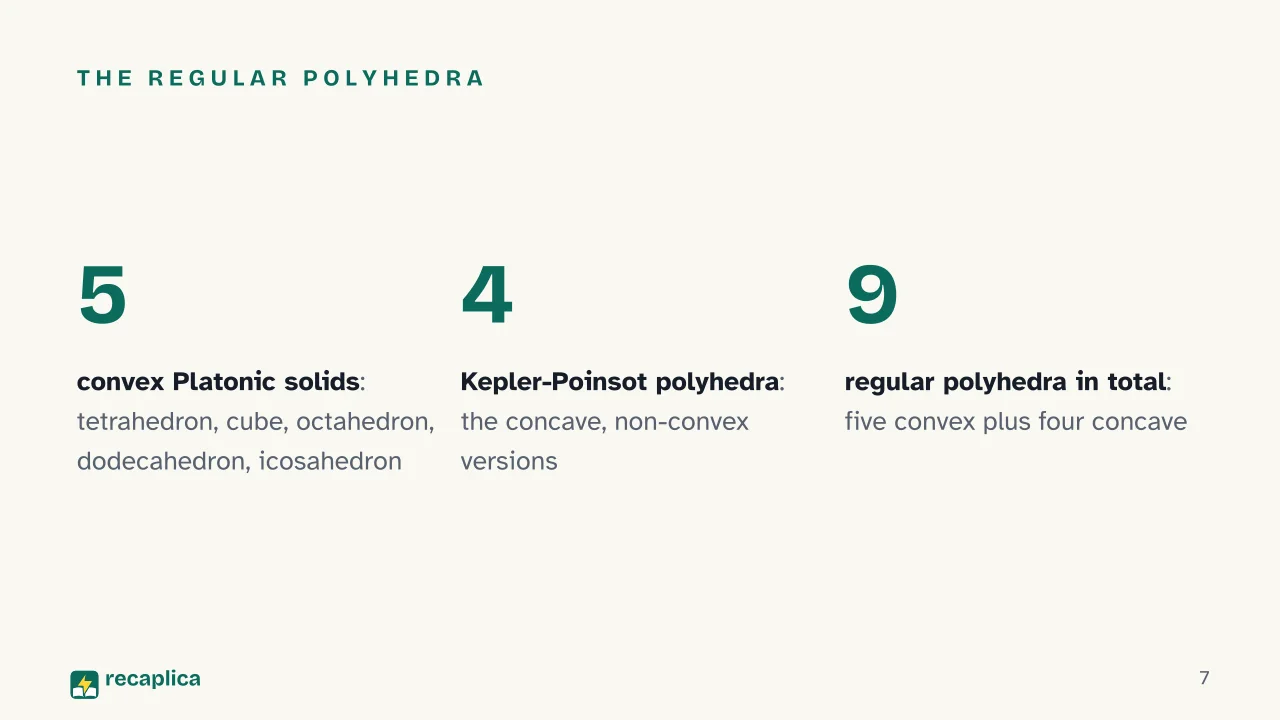
    • There are exactly five convex Platonic solids: the tetrahedron, cube, octahedron, dodecahedron, and icosahedron, the only polyhedra with faces and vertices that are all equivalent to one another.
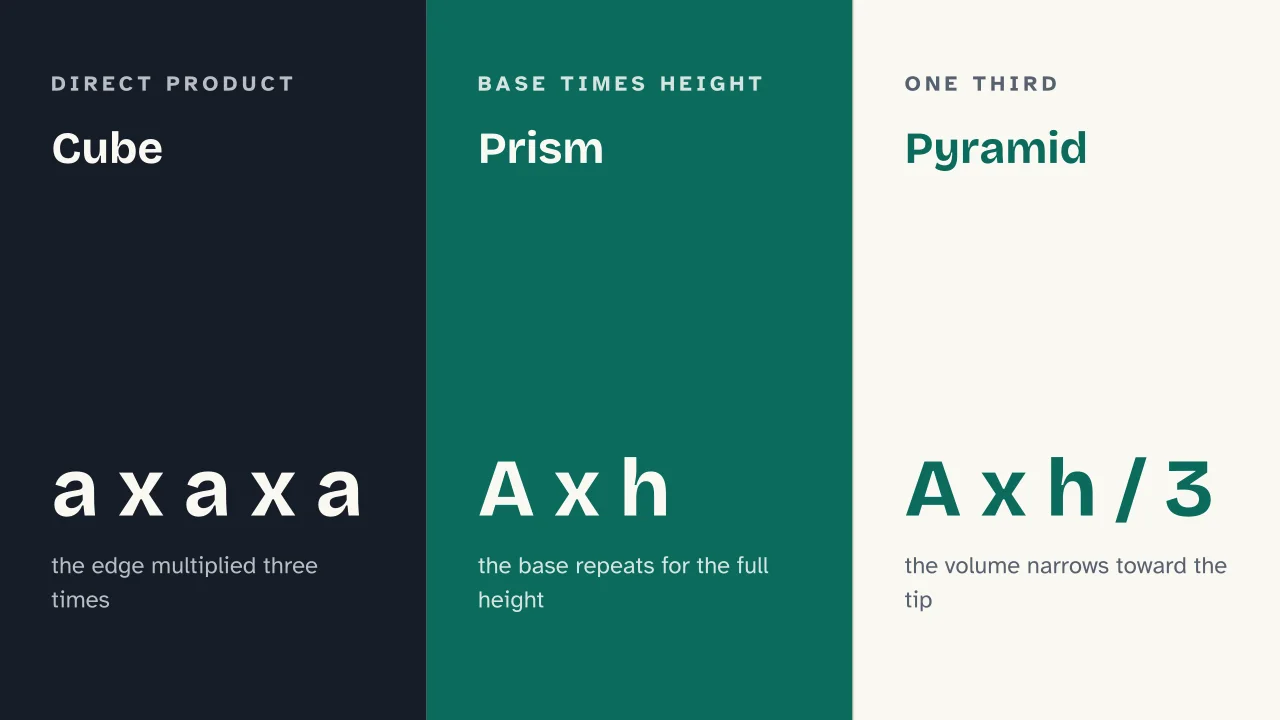
    • The volume of a prism is its base area times its height; a pyramid's is one third of that, because the shape narrows toward its apex.
    • Cylinders, cones, and spheres are solids of revolution: they form when a flat shape spins 360 degrees around an axis.
    • Lateral surface area leaves out the bases; total surface area includes them — two different measurements for two different jobs.
    • Plane geometry studies shapes in two-dimensional space; solid geometry studies them in three dimensions.

    Deep Dive

    What a Solid Is

    A solid, according to the entry Treccani devotes to the term in its Enciclopedia della Matematica, is a three-dimensional shape in ordinary space, made up of a closed and bounded set of points. The boundary of that shape is its surface, which can be flat, curved, or a mix of both, depending on the solid. When the surface is made entirely of polygons joined along their edges, the solid is called a polyhedron.

    The volume of a solid is the intuitive measure of the space it takes up. Working it out means matching the volume to measurements of a few defining elements of the solid — edges, heights, radii — different for every kind of shape. Solid geometry runs on the same basic tools as Euclidean geometry: points, lines, and planes, applied to three-dimensional space instead of a flat sheet.

    Polyhedra and the Five Platonic Solids

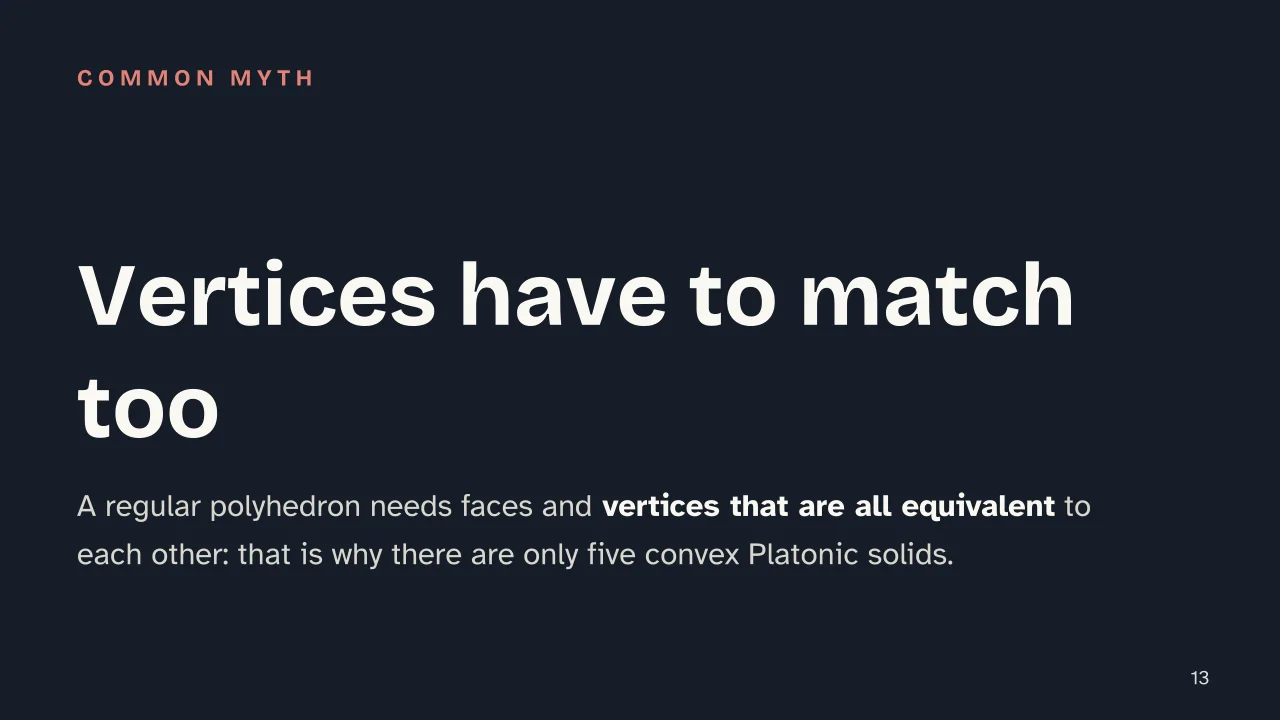
    A polyhedron, per Wolfram MathWorld, is a three-dimensional solid made up of a collection of polygons joined along their edges. Some polyhedra are regular: that happens when both their faces and their vertex figures are regular polygons, meaning faces and vertices are both equivalent to one another.

    There are exactly five convex regular polyhedra, the Platonic solids: the tetrahedron, cube, octahedron, dodecahedron, and icosahedron. Add their concave, stellated counterparts, the four Kepler-Poinsot polyhedra, and the total number of regular polyhedra rises to nine.

    Among the most common polyhedra in everyday use are shapes that are not regular but just as useful: the cuboid (a box with three pairs of opposite rectangular faces), the prism (two matching, parallel polygonal bases joined by side faces), and the pyramid (one polygonal base with triangular faces meeting at a single vertex, the apex).

    Surface Area and Volume Formulas for Polyhedra

    Formulas swap numbers for letters — the same symbolic notation at the core of algebra — because they need to hold for any measurement of a given type of solid.

    SolidSurface AreaVolume
    Cube (edge a)S = 6a²V = a³
    Cuboid (edges a, b, c)S = 2(ab + bc + ca)V = abc
    Right prism (base area A, base perimeter p, height h)lateral = p × hV = A × h
    Right pyramid (base area A, base perimeter p, slant height a, height h)lateral = (p × a) / 2V = (A × h) / 3

    Two things hold across the whole table. First: a prism and a cylinder share the same volume logic, base area times height, because the solid’s cross section stays identical from bottom to top. Second: a pyramid and a cone cut that logic down to a third, because the cross section shrinks on the way to the apex — Wolfram MathWorld notes that this holds for any shape of base, since the area of a cross section scales quadratically with height.

    A prism’s lateral surface area, base perimeter times height, is the same rule that applies to a cylinder too (see below): both solids have a lateral surface that unrolls flat into a rectangle.

    Cylinders, Cones, and Spheres, the Solids of Revolution

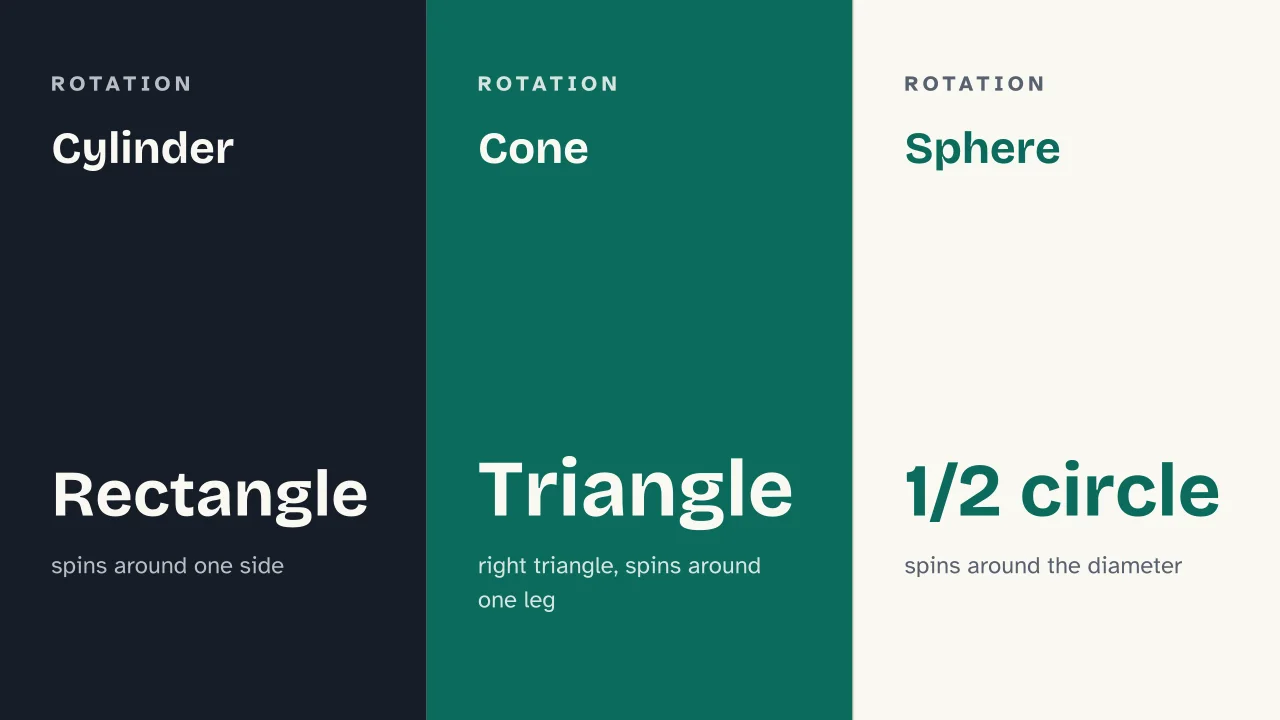
    Cylinders, cones, and spheres are not polyhedra: their surfaces are curved, not made of polygons. They are called solids of revolution because they form when a flat shape spins 360 degrees around a line, the axis of rotation. A rectangle spun around one of its sides generates a cylinder; a right triangle spun around one leg generates a cone; a semicircle spun around its diameter generates a sphere.

    This Recap stops at the definition and the formulas for these three common solids of revolution. Working out the volume of a general solid of revolution, formed by spinning an arbitrary curve instead of a basic shape, belongs to calculus.

    Surface Area and Volume Formulas for Solids of Revolution

    SolidSurface AreaVolume
    Cylinder (radius r, height h)lateral = 2πrh · total = 2πr(r+h)V = πr²h
    Cone (radius r, height h, slant height a = √(r²+h²))lateral = πra · total = πr(r+a)V = (πr²h) / 3
    Sphere (radius r)S = 4πr²V = (4/3)πr³

    The formulas for cylinder, cone, and sphere show up, in the same form, on both Wolfram MathWorld and the math.it solid-geometry formula reference: two independent sources confirming each other. The sphere formulas in particular have a long history — MathWorld traces both to Archimedes, first derived in his treatise On the Sphere and Cylinder, around 225 BCE.

    Practical example: A cylinder has a base radius of 3 cm and a height of 7 cm. Its volume comes from V = πr²h: 3 squared is 9, 9 times 7 is 63, so V = 63π cm³, about 197.9 cm³ using π ≈ 3.14159 — the same multiplication at the heart of arithmetic, applied to a solid instead of isolated numbers. The lateral surface area, meanwhile, is 2πrh: 2 times π times 3 times 7 is 42π cm², about 131.9 cm².

    How 3D Shapes Are Classified, and How They Differ from Plane Shapes

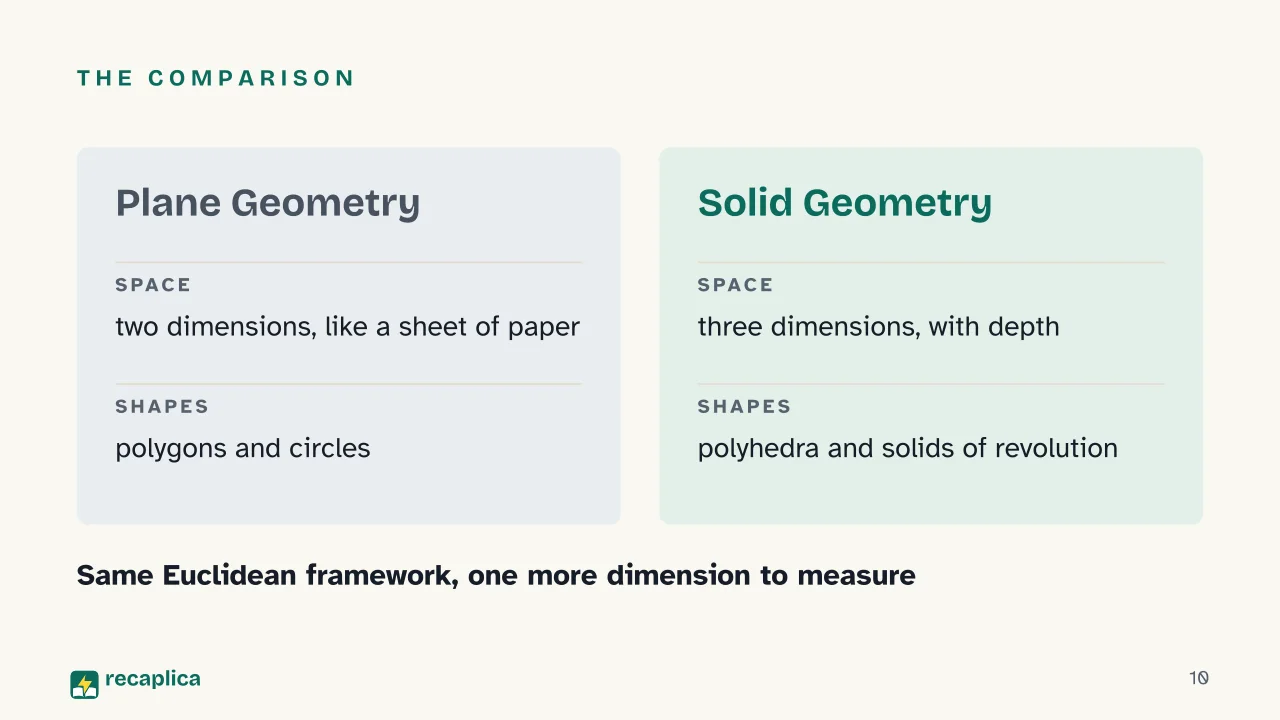
    Plane geometry, as Treccani defines it, studies the properties of shapes set in an ordinary two-dimensional Euclidean space: triangles, quadrilaterals, circles, and every other shape you can draw on a flat sheet. Solid geometry sits, by symmetry, in three-dimensional Euclidean space: it adds depth, and with it a surface to measure on top of a volume (the space it occupies).

    Plane shapes and solid shapes are not rivals: they are often the same shape seen through a different number of dimensions. A square is a plane shape; six matching squares joined along their edges form a cube, a polyhedron. A circle is a plane shape; a circle swept along an axis, for the height of a cylinder, generates a solid of revolution. Telling whether a problem is about a plane shape or a solid is the first step toward picking the right formula: area formulas (in two dimensions) and surface-area-and-volume formulas (in three) are not interchangeable.

    Slide deck

    Slides ready to download and make your own in PowerPoint or Google Slides, with speaker notes. Pick the Flash cut or the Full one.
    Slide 1 of the presentation on Solid Geometry: Solid GeometrySlide 2 of the presentation on Solid Geometry: Why are there only five regular polyhedra?Slide 3 of the presentation on Solid Geometry: The routeSlide 4 of the presentation on Solid Geometry: Chapter 01: What a Solid IsSlide 5 of the presentation on Solid Geometry: The key terms: Solid, Polyhedron, Solid of RevolutionSlide 6 of the presentation on Solid Geometry: Chapter 02: Polyhedra and the Platonic SolidsSlide 7 of the presentation on Solid Geometry: The regular polyhedraSlide 8 of the presentation on Solid Geometry: Chapter 03: Surface Area and Volume FormulasSlide 9 of the presentation on Solid Geometry: Cube · Prism · PyramidSlide 10 of the presentation on Solid Geometry: The comparisonSlide 11 of the presentation on Solid Geometry: Chapter 04: Rotation and Plane GeometrySlide 12 of the presentation on Solid Geometry: Cylinder · Cone · SphereSlide 13 of the presentation on Solid Geometry: Vertices have to match tooSlide 14 of the presentation on Solid Geometry: How many convex Platonic solids are there?Slide 15 of the presentation on Solid Geometry: Next step
    Flash10 slidesThe essential thread, to present in classFull15 slidesEvery chapter and the deeper detail

    Common myths

    • ✗ Myth A polyhedron is regular as long as all its faces match.

      ✓ Reality Two conditions have to hold at once, not one: the faces AND the vertices must all be equivalent to each other. That is why there are only five convex regular polyhedra, not a longer list of solids with identical faces — a solid can have congruent faces and still have vertices that differ from one another, and in that case it is not regular.

    • ✗ Myth A cylinder or a cone has just one surface area.

      ✓ Reality Lateral and total surface area are two different numbers, used for two different jobs: the lateral area is only the curved band, the total adds the circular bases. Someone wrapping a pipe needs the lateral figure; someone building a bucket needs the total, bases included.

    • ✗ Myth A pyramid with the same base and height as a prism has the same volume.

      ✓ Reality A pyramid's volume is one third of the prism's, not equal to it: a prism keeps the same cross-sectional area all the way up, while a pyramid shrinks down to a single point, and that narrowing cuts the final volume by more than half.

    Mind map

    Drag the background to move around and the nodes to reposition them; use − and + to collapse and expand branches.
    Customize
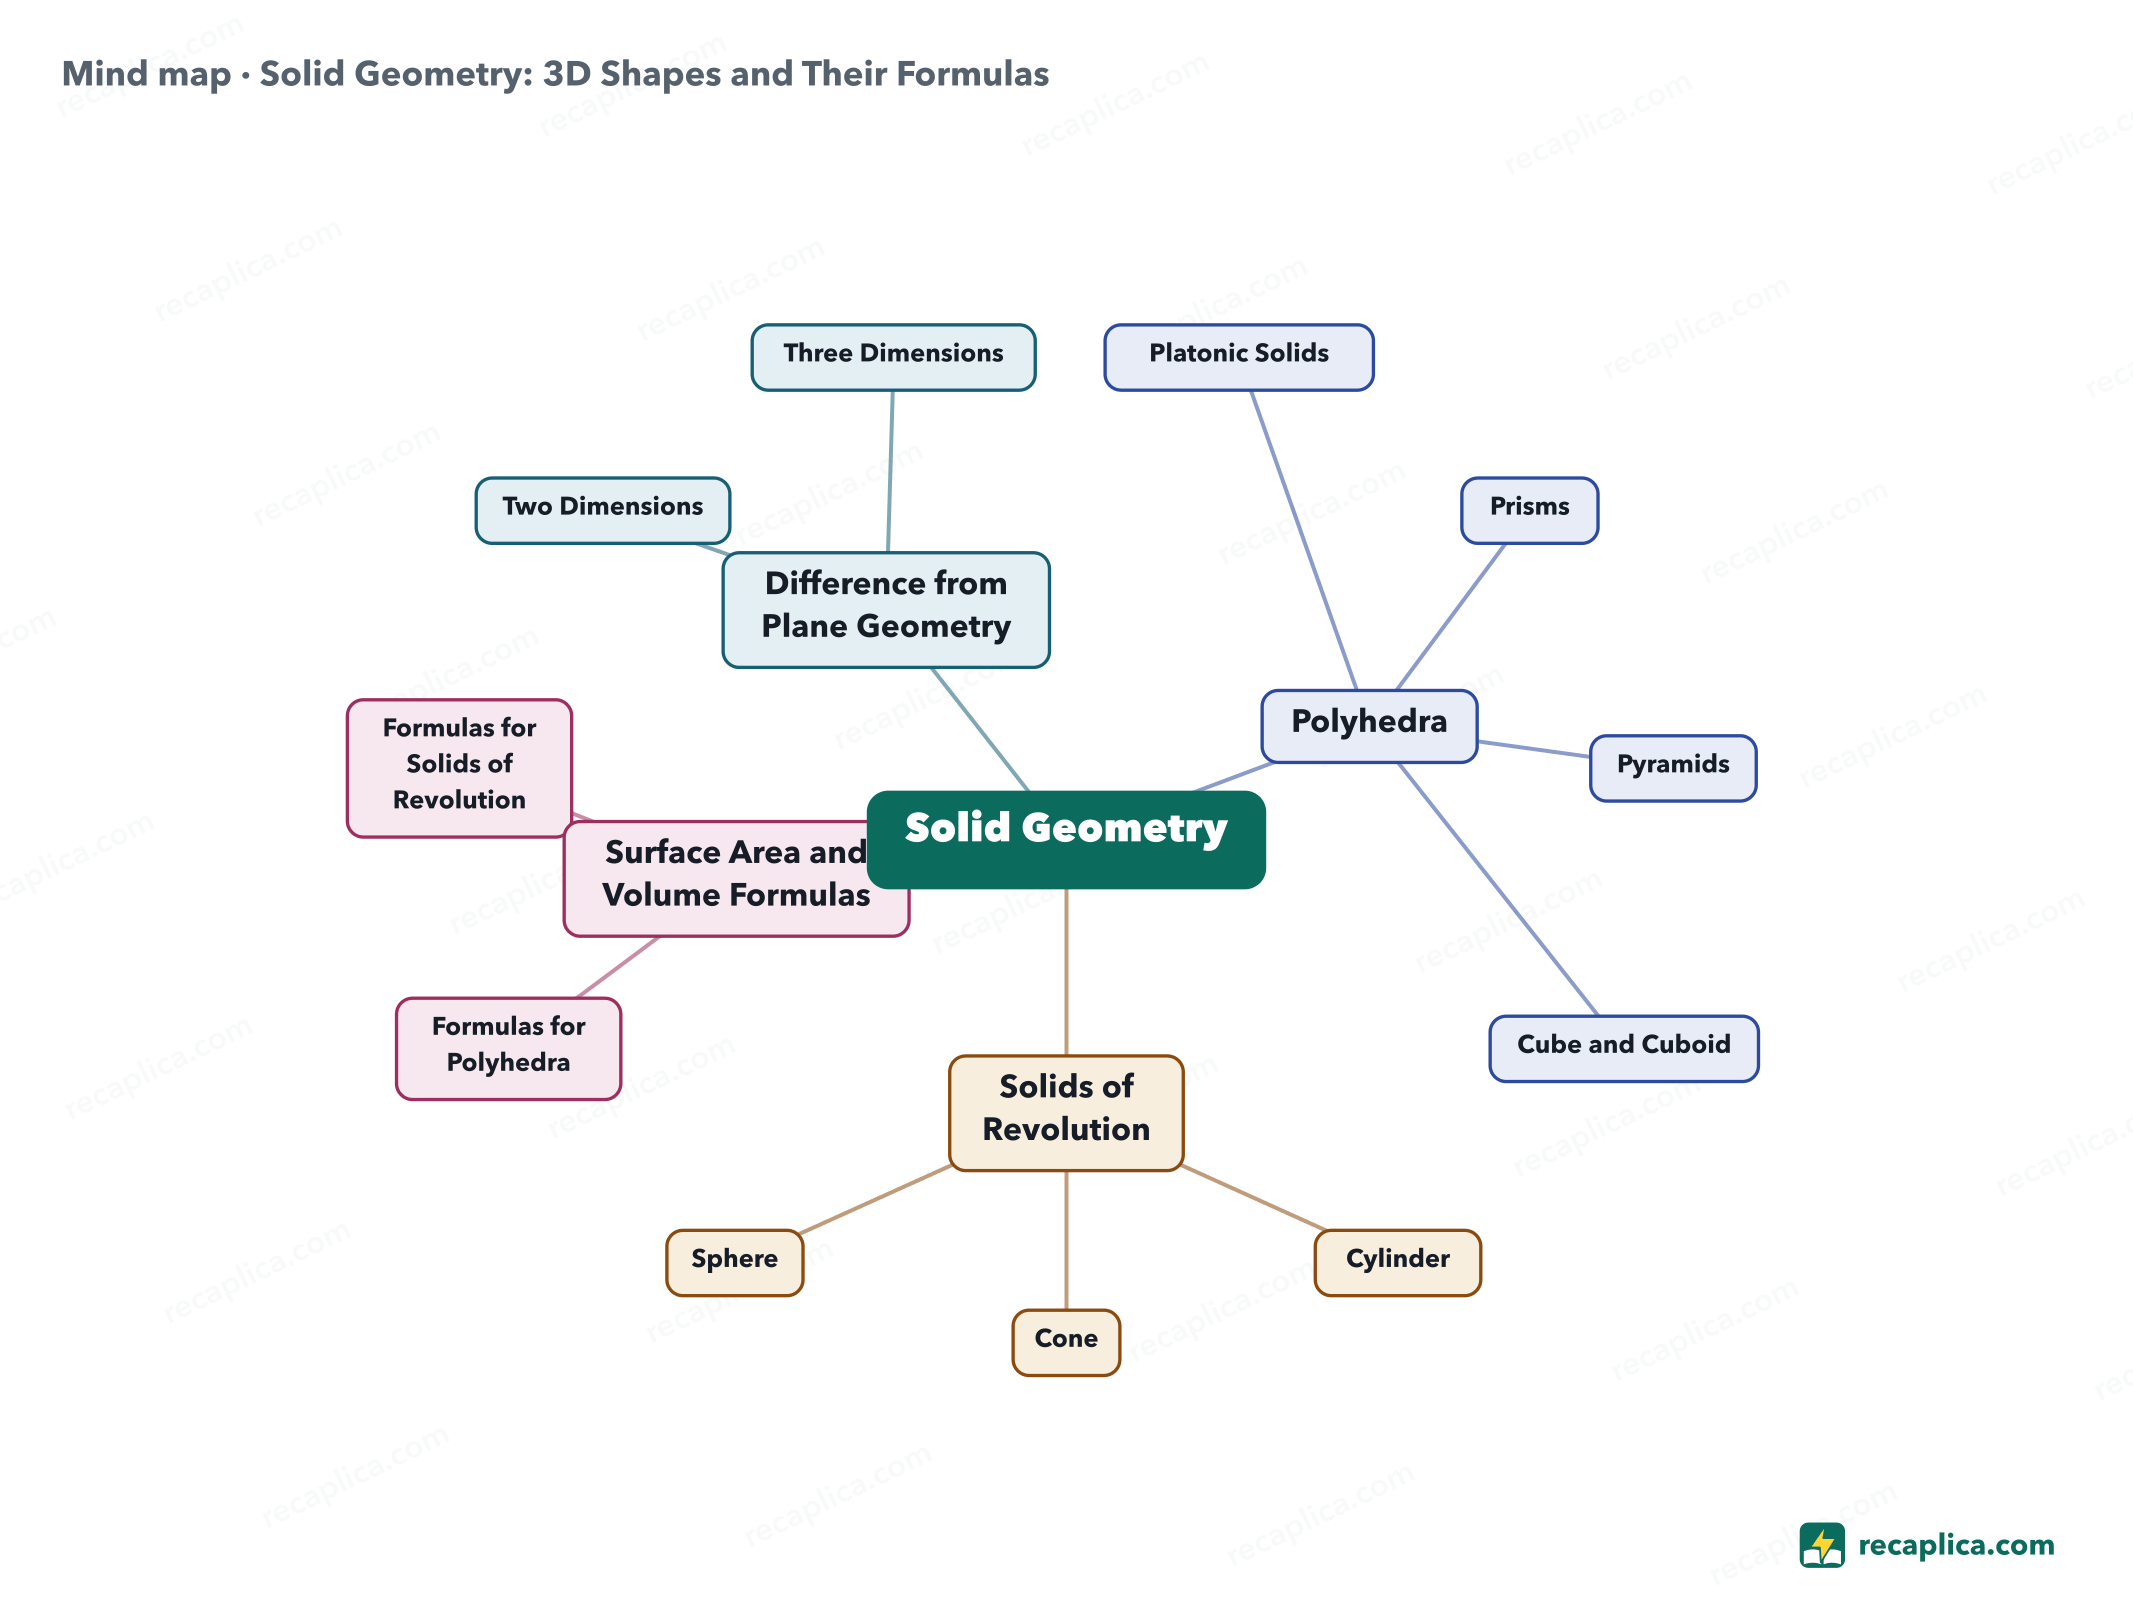
    Mind map: Solid Geometry: 3D Shapes and Their Formulas
    • Solid Geometry
      • Polyhedra
        • Platonic Solids the five convex regular polyhedra
        • Prisms two matching bases, rectangular sides if right
        • Pyramids one base, triangular faces meeting at the apex
        • Cube and Cuboid special cases of a rectangular-based prism
      • Solids of Revolution
        • Cylinder formed by rotating a rectangle
        • Cone formed by rotating a right triangle
        • Sphere formed by rotating a semicircle
      • Surface Area and Volume Formulas
        • Formulas for Polyhedra cube, cuboid, prism, pyramid
        • Formulas for Solids of Revolution cylinder, cone, sphere
      • Difference from Plane Geometry
        • Two Dimensions polygons and circles on a flat surface
        • Three Dimensions polyhedra and solids of revolution in space

    Quiz: test yourself

    Answer the questions to check what you have learned: you get instant feedback and a short explanation.

    Grade 0/10 0/5
    1 What is a polyhedron?

    A polyhedron is a solid whose surface is made of polygons joined along their edges; cylinders, cones, and spheres instead have curved surfaces and are solids of revolution, not polyhedra.

    2 How many convex Platonic solids are there?

    There are exactly five convex Platonic solids: the tetrahedron, cube, octahedron, dodecahedron, and icosahedron. Add the four concave Kepler-Poinsot polyhedra and the total climbs to nine regular polyhedra.

    3 What is the formula for the volume of a cylinder with radius r and height h?

    The volume of a cylinder is its base area (pi times r squared) times its height h. The other formulas are, in order, the cylinder's lateral surface area, the volume of a sphere, and the volume of a cone.

    4 How is a solid of revolution like a cone generated?

    A cone forms when a right triangle spins 360 degrees around one of its two legs; in the same way, a rectangle generates a cylinder and a semicircle generates a sphere.

    5 What is the difference between plane geometry and solid geometry?

    Plane geometry studies the properties of shapes in a two-dimensional Euclidean space, while solid geometry deals with shapes in three-dimensional Euclidean space, with its own formulas for surface area and volume.

    Answers: 1-A · 2-B · 3-A · 4-A · 5-A

    Flashcards

    Tap the card to flip it and check whether you remember the answer, then move to the next one.

    1 / 8

    Explain it in your own words

    The ultimate test: if you can explain it in simple words, you've truly understood it. Write your explanation, then compare it with the Recap.

    Your explanation is saved only on this device.

    Solid geometry is the branch of geometry that studies three-dimensional shapes: polyhedra, such as the cube and the pyramid, and solids of revolution, such as the cylinder, the cone, and the sphere. Every solid has its own formulas for surface area, the extent of its outer "skin," and volume, the space it occupies, built from measurements such as edges, radii, and heights. Where plane geometry works on a flat, two-dimensional surface, solid geometry adds depth, and each shape needs its own formula to match. Knowing these formulas is how you work out how much material a container needs or how much liquid it holds.

    Frequently asked questions

    What is solid geometry, in summary?

    It is the branch of geometry that studies three-dimensional shapes: polyhedra, such as the cube and the pyramid, and solids of revolution, such as the cylinder, the cone, and the sphere, along with the formulas for their surface area and volume.

    What are the names of the basic solid shapes in math?

    The main groups are polyhedra with flat polygon faces — cube, cuboid, prism, pyramid — and solids of revolution with curved surfaces, generated by spinning a flat shape around an axis: cylinder, cone, and sphere.

    How are 3D shapes classified and told apart from 2D shapes?

    A 2D, or plane, shape — a triangle, a square, a circle — exists on a flat surface and has only an area. A 3D, or solid, shape occupies space and has both a surface area and a volume; solids split further into polyhedra, bounded by flat polygon faces, and solids of revolution, bounded by at least one curved surface.

    What are the five Platonic solids?

    The tetrahedron, cube, octahedron, dodecahedron, and icosahedron: the five convex polyhedra whose faces and vertex figures are all regular and identical to one another.

    How do you calculate the volume of a cone?

    With the formula V = (pi × r² × h) / 3, where r is the radius of the circular base and h is the height: one third of the volume of a cylinder with the same base and height.

    Sources

    • Treccani, Solido, Enciclopedia della Matematica
    • Treccani, Geometria piana, Enciclopedia della Matematica
    • Wolfram MathWorld, Polyhedron
    • Wolfram MathWorld, Platonic Solid
    • Wolfram MathWorld, Cube
    • Wolfram MathWorld, Cuboid
    • Wolfram MathWorld, Prism
    • Wolfram MathWorld, Pyramid
    • Wolfram MathWorld, Cylinder
    • Wolfram MathWorld, Cone
    • Wolfram MathWorld, Sphere
    • Math.it, Formulario di geometria solida, Piramidi
    • Math.it, Formulario di geometria solida, Solidi di rotazione
    • Wikipedia, On the Sphere and Cylinder

    Every Recap goes through an independent review before publication.

    Every evening, the day's new Recaps on our Telegram channel. Join the channel →

    Keep learning

    • Science Cognitive Load Theory: The Definition Behind Sweller's Research Cognitive load is the amount of working memory a task uses up while you learn something new. Psychologist John Sweller first described it in 1988, starting from research on problem solving: a strategy that is too demanding leaves little room to build stable mental structures. Later research distinguishes three types of load, intrinsic, extraneous, and germane, though part of the field treats the third as indistinguishable from the first. Cutting extraneous load, with worked examples or less cluttered materials, frees up mental room for actual learning. Read the Recap →
    • Science Cognitivism: how the mind processes information Cognitivism is the psychological paradigm that treats the mind as a system for processing information, spanning perception, memory, reasoning and language. The shift began around 1956, while behaviorism, championed by Watson and Skinner, still ruled academic psychology and reduced the field to observable stimuli and responses. That same year, George Miller exposed the limits of short-term memory, and Chomsky joined McCarthy, Minsky, Newell and Simon in laying the groundwork for cognitive science. Donald Broadbent's attention model in 1958 and Ulric Neisser's 1967 book, which put the name cognitive psychology into common use, complete the roster of its founding figures. Read the Recap →
    • Science Behaviorism: What It Is and Where It Came From Behaviorism is the school of psychology that studies only observable behavior, leaving aside the thoughts and feelings that stay hidden inside the mind. It began in 1913, when the American psychologist John B. Watson published an essay calling for psychology to become an experimental science, without relying on introspection. After him, Ivan Pavlov studied conditioned reflexes and Edward Thorndike studied trial-and-error learning; Burrhus Skinner pushed the ideas to their most extreme form with radical behaviorism. The thread running through all of it is the stimulus-response model: a behavior is explained by what comes before it and what follows it, not by guessing what happens inside the head of the person doing it. Read the Recap →

    recaplica

    Clear in 30 seconds, yours in 10 minutes.

    Recaps Mind maps Request a Recap Telegram channel Mind map maker Our method About Privacy & cookies Legal notes & terms of use

    © 2026 Recaplica · A project by Curi S.r.l. — VAT IT05472000750

    Statistics, only if you say so

    To learn which Recaps help most we would use Google Analytics, with aggregate, anonymous data. It starts only with your OK, and you can change your mind anytime. Privacy policy